Changgao Xia1, Chenxi Sun1, and Jiangyi Han1
1College of Automotive and Traffic Engineering, Jiangsu University, Zhenjiang 212013, P.R. China
Received: February 26, 2020
Accepted: May 15, 2020
Publication Date: May 10, 2026
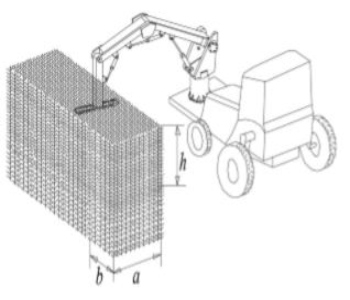
4-DOF manipulator trimming structure.
Copyright The Author(s). This is an open access article distributed under the terms of the Creative Commons Attribution License (CC BY 4.0), which permits unrestricted use, distribution, and reproduction in any medium, provided the original author and source are cited.
Download Citation: BibTeX | http://dx.doi.org/10.6180/jase.202009_23(3).0017
In order to improve the quality and efficiency of hedge trimming, a research of a four-degree-of-freedom trimming manipulator is carried out in this paper. The global kinematic performance metric (that is, the Global Condition Index constructed by the Jacobian matrix) is utilized to measure the dexterity of the manipulator. Then the structural parameter optimization model is established using the maximum Global Condition Index (GCI) as the objective function and the particle swarm algorithm is used to solve the optimization problem. The optimal link lengths (big arm, middle arm forearm) of the manipulator are 1190, 937, and 633mm, the initial GCI is 0.68442, and the optimized value is 0.79521. Obviously, the dexterity is higher. To verify the feasibility of the optimized manipulator, this paper proposes a method to evaluate the workspace, using accessibility to express how much the actual workspace satisfies the target workspace. Simulation results show that the reachability of optimized manipulator is 100%, improved by 11.21%, which proves that the optimized manipulator is completely feasible.
Keywords: Trimming manipulator; Global Condition Index; optimization; workspace
- [1] Q Wei. Research and design of double-sided high-efficiency hedge trimmer. Guangxi: Guangxi University, 2014.
- [2] YJ Wang. Structural parameters optimization of multidegree-of-freedom manipulator. Beijing: Beijing Institute of Technology, 2016.
- [3] X W Wang, M H Wu, and J Zhou. Optimization and simulation of structural parameters of manipulators for high-quality tea picking robots. Journal of Chinese Agricultural Mechanization, 39(7):84–89, 2018.
- [4] Haibo Tian, Hongwei Ma, and Juan Wei. Workspace and structural parameters analysis for manipulator of serial robot. Nongye Jixie Xuebao/Transactions of the Chinese Society for Agricultural Machinery, 44(4):196–201, 2013.
- [5] JK Salisbury and JJ Craig. Articulated hands: Kinematic and force control issues. The International Journal of Robotics Research, 1(1):4–17, 1982.
- [6] J. Angeles. A global performance index for the kinematic optimization of robotic manipulators. Journal of Mechanical Design, Transactions of the ASME, 113(3):220226, sep 1991.
- [7] G Tang. Research on kinetic characteristics of express-way hedgerow pruning robot. Chongqing: Chongqing Jiaotong University, 2018.
- [8] Zhizhong Liu, Hongyi Liu, Zhong Luo, and Xiuheng Zhang. Improvement on Monte Carlo method for robot workspace determination. Nongye Jixie Xuebao/Transactions of the Chinese Society for Agricultural Machinery, 44(1):230–235, jan 2013.
- [9] RPYe. Research on modeling and simulation of 5-DOF serial manipulator. Shenzhen: Shenzen University, 2016.
- [10] Geoffrey Pond and Juan A. Carretero. Quantitative dexterous workspace comparison of parallel manipulators. Mechanism and Machine Theory, 42(10):1388–1400, oct 2007.
- [11] Mengke Qu, Hongbo Wang, and Yu Rong. Design of 6-DOF parallel mechanical leg of wheel-leg hybrid quadruped robot. Nongye Gongcheng Xuebao/Transactions of the Chinese Society of Agricultural Engineering, 33(11):29–37, 2017.
- [12] Yu Rong, Zhenlin Jin, and Bingyan Cui. Configuration analysis and structure parameter design of six-leg agricultural robot with parallel-leg mechanisms. Nongye Gongcheng Xuebao/Transactions of the Chinese Society of Agricultural Engineering, 28(15):9–14, 2012.
- [13] Lung Wen Tsai and Sameer Joshi. Kinematics and optimization of a spatial 3-UPU parallel manipulator. Journal of Mechanical Design, Transactions of the ASME, 122(4):439–446, 2000.
- [14] H F Wang, B Yin, and R J Luo. Mechanism design and kinematics analysis of 4-dof SCARA robot system. Journal of Mechanical & Electrical Engineering, 36(12):1320–1324, 2019.
- [15] Arkadeep Narayan Chaudhury and Ashitava Ghosal. Optimum design of multi-degree-of-freedom closed-loop mechanisms and parallel manipulators for a prescribed workspace using Monte Carlo method. Mechanism and Machine Theory, 118:115–138, 2017.
- [16] Z Cai and B Xie. Robotics. Third Edition, Beijing: Tsinghua University Press, pages 8–9, 2015.
- [17] J Song. Optimization design and simulation on structure parameter of eggplant picking robot. Mechanical Design & Manufacture, (6):166–168, 2008.
- [18] J Wei. Design and Research of Hedge Seedling Pruning Manipulator. Guangxi: Guangxi University, 2013.
- [19] H Z Li, Z G Hu, and L J Guo. Simulation study of manipulator with three degree of freedom. Mechanical Design & Manufacture, (10):186–189, 2014.
- [20] Y D Fu. The design and research of mechanism and control system of the cucumber harvesting manipulator. Jilin, Jilin University, 2016.
- [21] Tuomo Kivelä, Jouni Mattila, and Jussi Puura. A generic method to optimize a redundant serial robotic manipulator’s structure. Automation in Construction, 81:172–179, 2017.
- [22] Serdar Küçük and Zafer Bingül. Robot workspace optimization based on the global conditioning index. In IFAC Proceedings Volumes, volume 36, pages 117–122. IFAC Secretariat, 2003.
- [23] Virendra Kumar, Soumen Sen, Shibendu S. Roy, Chandan Har, and S.N. Shome. Design Optimization of Serial Link Redundant Manipulator: An Approach Using Global Performance Metric. Procedia Technology, 14:43–50, 2014.
- [24] Hyun Seop Lim, Soon Woong Hwang, Kyoo Sik Shin, and Chang Soo Han. Design optimization of the robot manipulator based on global performance indices using the grey-based taguchi method. In IFAC Proceedings Volumes, volume 43, pages 285–292, 2010.
- [25] C. West, A. Montazeri, S. D. Monk, and C. J. Taylor. A genetic algorithm approach for parameter optimization of a 7DOF robotic manipulator. International Federation of Automatic Control, 49(12):1261–1266, 2016.
- [26] Yi Ye, Chen Bo Yin, Yue Gong, and Jun jing Zhou. Position control of nonlinear hydraulic system using an improved PSO based PID controller. Mechanical Systems and Signal Processing, 83:241–259, jan 2017.
- [27] Yi Cao, Haihe Zang, Lan Wu, and Tao Lu. An engineering-oriented method for the three dimensional workspace generation of robot manipulator. Journal of Information and Computational Science, 8(1):51–61, 2011.