Behnam Babaei and Masoud Shafiee
Department of Electrical Engineering, Amirkabir University of Technology, Iran
Received: January 26, 2018
Accepted: October 2, 2018
Publication Date: June 20, 2026
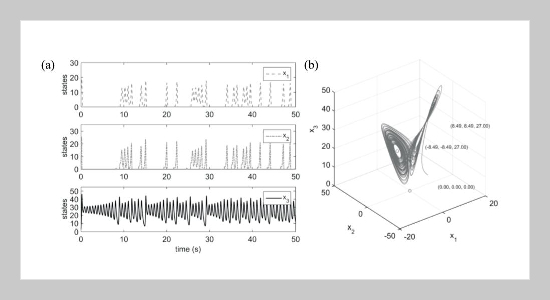
The chaotic behavior of the Lorenz system with initial point(10,5,3). (a) x1, x2 and x3 are unstablevs.time. (b) The trajectory attractton one of fixed points. This system has three fixed points as listed in Table1.
Copyright The Author(s). This is an open access article distributed under the terms of the Creative Commons Attribution License (CC BY 4.0), which permits unrestricted use, distribution, and reproduction in any medium, provided the original author and source are cited.
Download Citation: BibTeX | http://dx.doi.org/10.6180/jase.201903_22(1).0020
Chaos is a complicated phenomenon in nonlinear dynamical systems. A dynamic controller, based on the stability transformation method (STM), has been used to stabilize both multiple fixed points and unknown unstable periodic orbits (UPOs) in dynamical systems. However, in these methods, there is not any unified algorithm in order to stabilize the fixed points. Here, we present a universal and simple chaos control algorithm called method of selecting an unstable fixed point (SUFP), which is able to stabilize unstable selected fixed points, by generating a stability matrix. Although this algorithm modifies a system by applying an input feedback, the designed feedback does not relocate the positions of fixed points but changes their stabilities. Results show that all tested chaotic trajectories are attracted to selected points, independent of initial values.
Keywords: Stability Matrix, Chaotic System, Fixed Point, Selecting Unstable Fixed Point, SUFP, Eigenvalue, Algorithm, Lorenz Model
- [1] Ott, E., C. Grebogi, and J. A. Yorke (1990) Controlling Chaos, Physical Review Letters 64, 1196. doi: 10.1103/PhysRevLett.64.1196
- [2] Gritli, H., S. Belghith, and N. Khraief (2015) Ogy-based control of Chaos in semi-passive dynamic walking of a torso-driven biped robot, Nonlinear Dynamics 79(2), 1363–1384. doi: 10.1007/s11071-014-1747-9
- [3] Gritli, H., and S. Belghith (2017) Walking dynamics of the passive compass-gait model under ogy-based control: Emergence of bifurcations and Chaos, Communications in Nonlinear Science and Numerical Simulation 47, 308–327. doi: 10.1016/j.cnsns.2016.11.022
- [4] Gritli, H., and S. Belghith (2018) Diversity in the non-linear dynamic behavior of a one-degree-of-freedom impact mechanical oscillator under ogy-based state-feedback control law: Order, Chaos and exhibition of the border-collision bifurcation, Mechanism and Machine Theory 124, 1–41. doi: 10.1016/j.mechmachtheory.2018.02.001
- [5] Kittel, A., J. Parisi, and K. Pyragas (1995) Delayed feedback control of Chaos by self-adapted delay time, Physics Letters A 198, 433–436. doi: 10.1016/0375-9601(95)00094-J
- [6] Fradkov, A. L., and A. Y. Pogromsky (1998) Introduction to Control of Oscillations and Chaos, Volume 35, World Scientific. doi: 10.1142/9789812798619_0004
- [7] Akhmet, M., and M. O. Fenm (2017) Unpredictable Sequences and Poincaré Chaos, arXiv preprint arXiv: 1704.06963.
- [8] Pyragas, K. (1992) Continuous control of Chaos by self-controlling feedback, Physics Letters A 170, 421–428. doi: 10.1016/0375-9601(92)90745-8
- [9] Rezaie, B., and M.-R. J. Motlagh (2011) An adaptive delayed feedback control method for stabilizing chaotic time-delayed systems, Nonlinear Dynamics 64, 167–176. doi: 10.1007/s11071-010-9855-7
- [10] Yan, Z. (2005) Controlling hyperchaos in the new hyperchaotic Chen system, Applied Mathematics and Computation 168(2), 1239–1250. doi: 10.1016/j.amc.2004.10.016
- [11] Dou, F. Q., J. A. Sun, W. S. Duan, and K. P. Lü (2009) Controlling hyperchaos in the new hyperchaotic system, Communications in Nonlinear Science and Numerical Simulation 14(2), 552–559. doi: 10.1016/j.cnsns.2007.10.009
- [12] Tao, C., C. Yang, Y. Luo, H. Xiong, and F. Hu (2005) Speed feedback control of chaotic system,” Chaos, Solitons & Fractals 23(1), 259–263. doi: 10.1016/j.chaos.2004.04.009
- [13] Azar, A. T., and S. Vaidyanathan (2015) Chaos Modeling and Control Systems Design, Volume 581, Springer. doi: 10.1007/978-3-319-13132-0_7
- [14] Tao, C., and C. Yang (2008) Three control strategies for the Lorenz chaotic system, Chaos, Solitons & Fractals 35(5), 1009–1014. doi:10.1016/j.chaos.2006.06.089
- [15] Zhu, C., and Z. Chen (2008) Feedback control strategies for the Liu chaotic system, Physics Letters A 372(22), 4033–4036. doi:10.1016/j.physleta.2008.03.018
- [16] Zhu, C. (2010) Controlling hyperchaos in hyperchaotic Lorenz system using feedback controllers, Applied Mathematics and Computation 216(10), 3126–3132. doi: 10.1016/j.amc.2010.04.024
- [17] Hilborn, R. C., S. Coppersmith, A. J. Mallinckrodt, S. McKay, et al. (1994) Chaos and nonlinear dynamics: an introduction for scientists and engineers, Computers in Physics 8, 689–689. doi: 10.1063/1.4823351
- [18] Sparrow, C. (2012) The Lorenz Equations: Bifurcations, Chaos, and Strange Attractors, Volume 41, Springer Science & Business Media.
- [19] Tabor, M., and J. Weiss (1981) Analytic structure of the Lorenz system, Physical Review A 24, 2157. doi: 10.1103/PhysRevA.24.2157
- [20] Etkin, D. (2014) Disaster Theory: an Interdisciplinary Approach to Concepts and Causes, Butterworth-Heinemann.
- [21] Boeing, G. (2016) Visual analysis of nonlinear dynamic systems: chaos, fractals, self-similarity and the limits of prediction, Systems 4, 37. doi: 10.3390/systems4040037
- [22] Kuznetsov, N. (2016) The Lyapunov dimension and its estimation via the Leonov method, Physics Letters A 380(25–26), 2142–2149. doi: 10.1016/j.physleta.2016.04.036
- [23] Dadras, S., H. R. Momeni, and G. Qi (2010) Analysis of a new 3D smooth autonomous system with different wing chaotic attractors and transient Chaos, Nonlinear Dynamics 62(1–2), 391–405. doi: 10.1007/s11071-010-9726-2